Robotic milling of a 1-metre hand sculpture from a 3D scan
From a 3D scan to a 1-metre sculpture
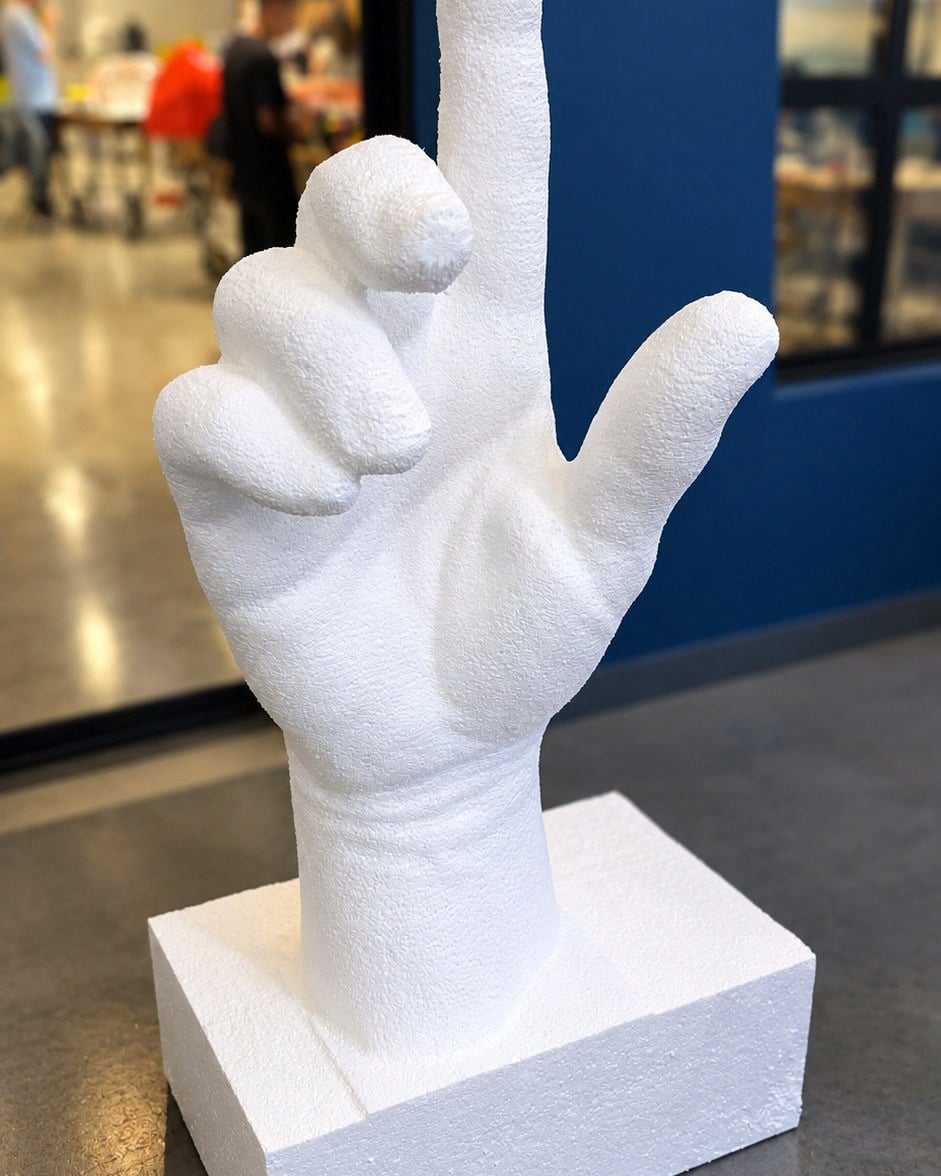
Thanks to MecDATA SCP for sharing this end-to-end project: an original hand sculpture was digitised, prepared in Rhino and milled from polystyrene by a KUKA robot programmed in ENCY Robot. The finished hand stands one metre tall.
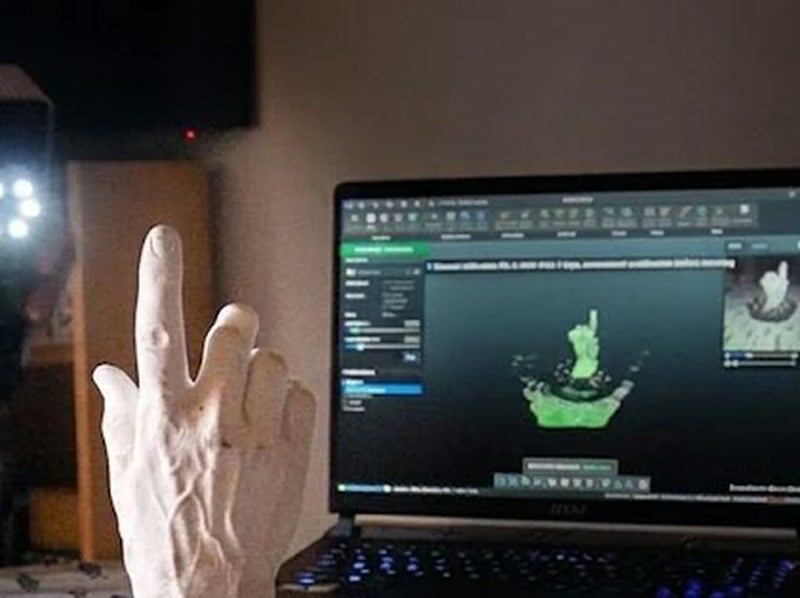
Phase 1: High-precision 3D scanning with 3DeVOK
The starting point was a 3D digitisation of the original hand sculpture with a 3DeVOK scanner (MecDATA is the official 3DeVOK distributor in Spain). The scan captured every volume, fold and anatomical detail and produced a clean polygon mesh faithful to the real model — the geometric basis for modelling in Rhino and toolpath preparation in ENCY Robot.
Phase 2: CAD preparation in Rhino
The mesh was imported and analysed, with polygon density checked and scan geometry cleaned up. The hand was then scaled proportionally to its final height of one metre, positioned precisely relative to the work origin with the reference planes the KUKA robot would use, and checked to be watertight so that no surface gaps would cause errors during CAM toolpath calculation.
Phase 3: Toolpath programming and simulation in ENCY Robot
With the geometry scaled and positioned, MecDATA moved to ENCY Robot to calculate the machining toolpaths and simulate the complete robotic cell. The KUKA kinematics and external axes were configured for continuous, smooth passes around the part. 5- and 6-axis roughing and finishing toolpaths were generated for the organic shapes and anatomical details. The whole work environment — KUKA arm, spindle, tool, part and rotary table — was simulated to detect and avoid any collision before real machining in the shop.
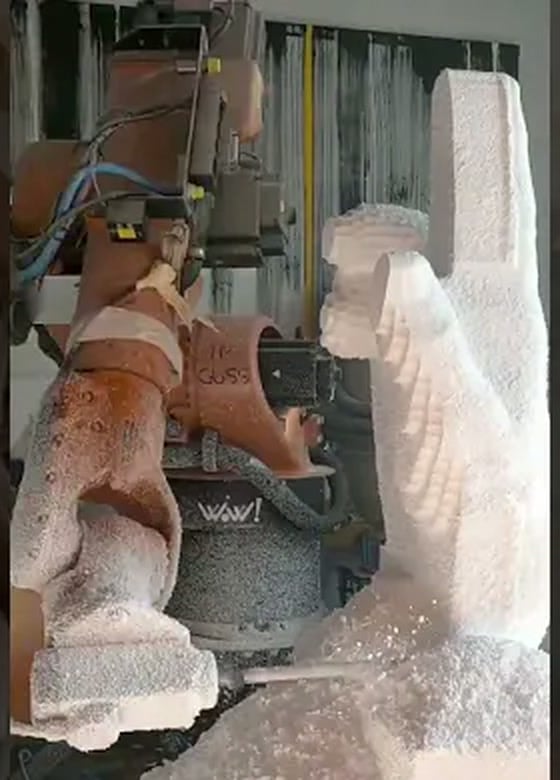
Phase 4: Real machining with the KUKA robot
After virtual validation in ENCY Robot, the KUKA arm milled the full-scale hand. Progressive roughing removed material while keeping the robot stable and accurate, and finishing passes delivered the surface smoothness and detail the organic, anatomical forms of the artwork required.
The result
A one-metre polystyrene sculpture produced from a digital model obtained by 3D scanning — an integrated workflow connecting 3DeVOK scanning, Rhino design, ENCY Robot programming and robotic fabrication at MecDATA.
Products and Solutions
Product
ENCY Robot: A complete offline robot programming solutionView product